Projects
Four machines, newest first. Each one scrolls through its CAD, then the build photos and footage.
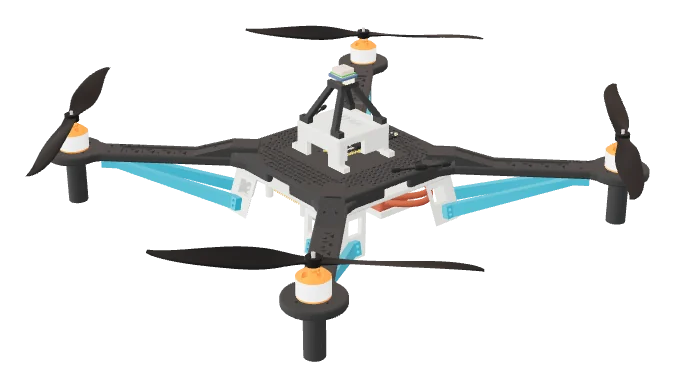
Titan: autonomous quadcopter
Mechanical
Designed and 3D printed a custom 50 cm frame in Fusion 360, now on its 6th iteration.
Electrical
Hand-soldered and wired all electronics (ESCs, UBECs, receiver, GPS, compass, power supply, flight controller peripherals) and tuned GPS/compass-based PID loiter through ArduPilot for stable positioning.
Software
Wrote a Python pipeline running on a Raspberry Pi 5 combining YOLOv8 object detection with a custom PID control loop for autonomous object-following, communicating with the flight controller over MAVLink.
Full build archive 4 photos, 2 videos
Phaethon: ground-effect vehicle (ekranoplan)
Concept
Researched cost-effective cargo transport by exploring ground/ram effect.
Build
An 80 cm foam airframe with two brushless motors and 5" propellers, hand-soldered ESCs, flight controller, GPS, motors/servos. Pitch, elevator, and thrust control, tested across 3S/2S LiPo to probe limits of efficient flight.
Results
Glided on water; measurable ground effect while tethered; draws 45 W at 600 g: 63% less power per kilogram than the quadcopter; weak control authority at low speed. Full-scale ekranoplans see 10 to 20x gains at cruise speed with optimal WIG geometry, suggesting this small low-speed prototype captured only part of the achievable effect.
Full build archive 4 photos, 2 videos
VEX V5: Over Under season
Design & Build
Large focus on innovative design, including two original mechanisms recognized as world firsts: ball-bearing-fitted omni-wheels for higher load capacity/lower rolling friction, and self-locking, detachable large components using linear slides.
Programming & Controls
Implemented PID-based speed control, odometry, and pure pursuit path tracking, plus a boomerang controller for autonomous positioning in PROS, with experimental Monte Carlo localization for robot pose estimation.
Results
9 awards, VEX World Championship Build Award, top-100 global/40,000+ teams, top-5 Canada, top 0.5% worldwide, international recognition.
Full build archive 4 photos, 4 videos
VEX V5: High Stakes season
Design & Build
Designed and machined competition robot subsystems using CAD (Inventor Professional 2025), iterating drivetrain and manipulator mechanisms across a 10-month build season.
Software
Rewrote the entire codebase from the ground up as a fully custom software stack, using outside libraries only for non-core support like GIF display and LED configuration. Added color-based object tracking with the VEX Vision Sensor to detect and react to game elements in real time.